A Comprehensive, Open-Source Vision-Language-Action Platform for Embodied AI
REALMIRROR
Cong Tai†, Zhaoyu Zheng†, Haixu Long†, Hansheng Wu, Haodong Xiang,
Zhengbin Long, Jun Xiong, Rong Shi, Shizhuang Zhang, Gang Qiu, He Wang,
Ruifeng Li, Jun Huang, Bin Chang, Shuai Feng, Tao Shen*
.
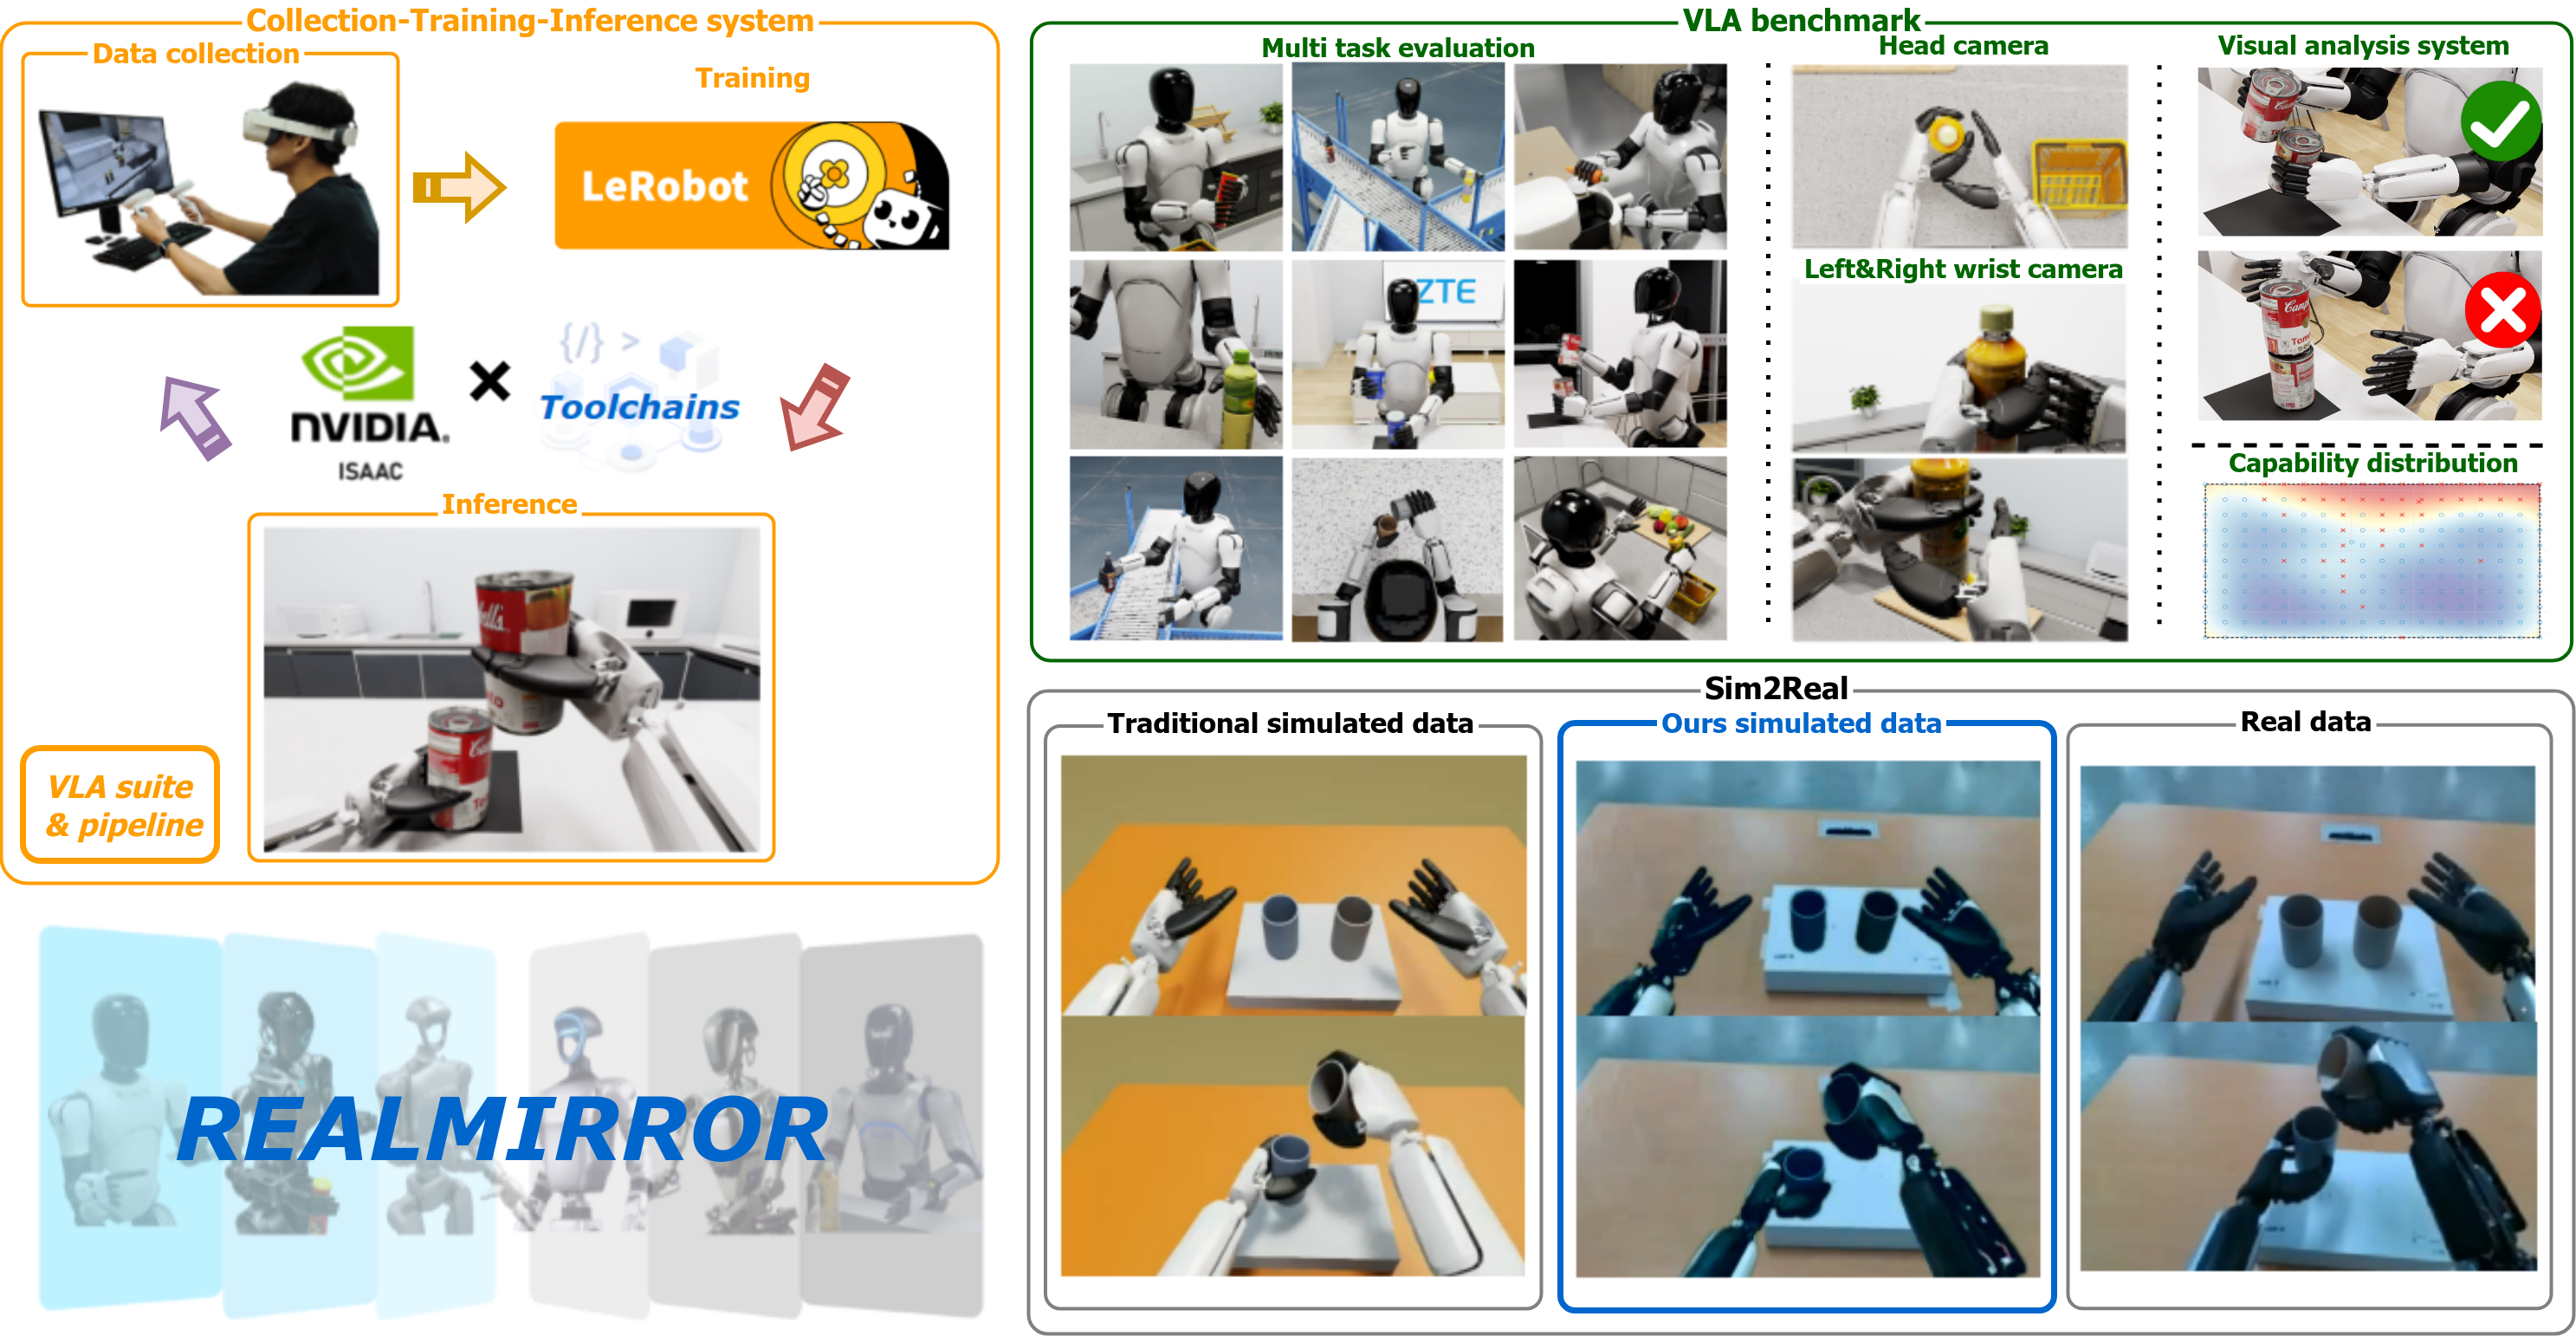
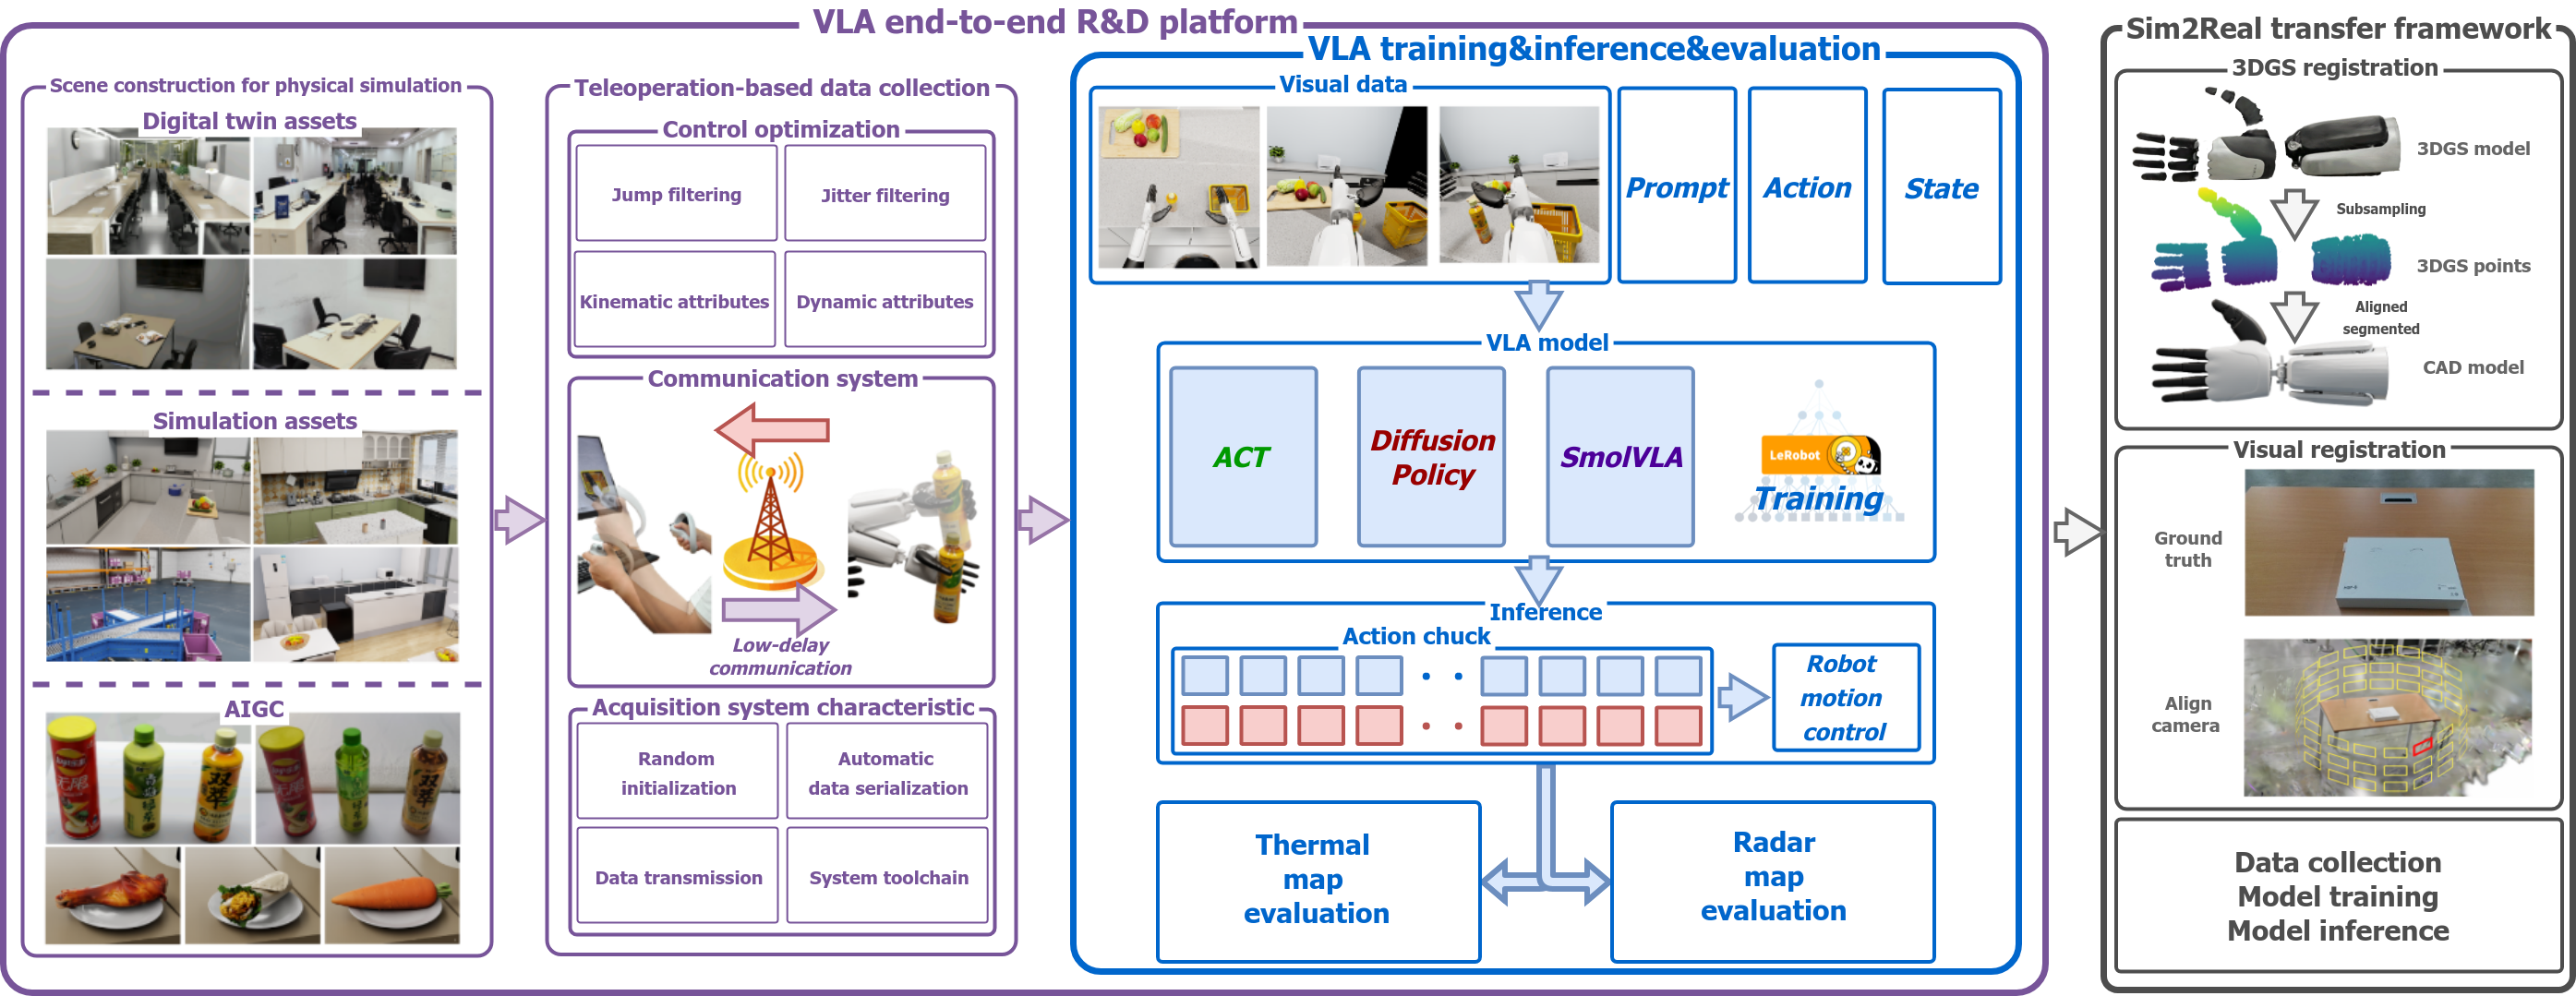
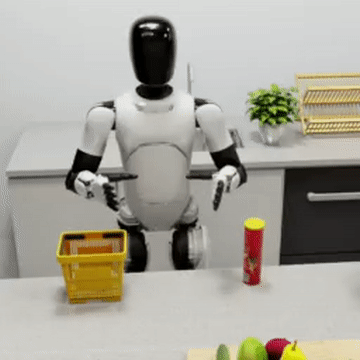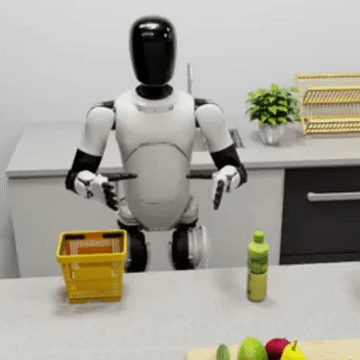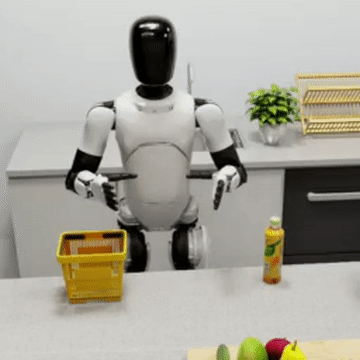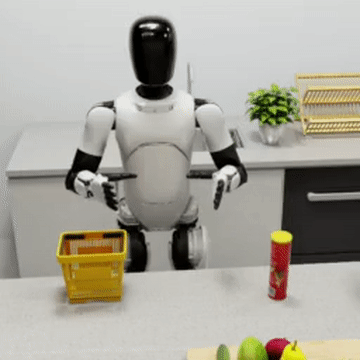
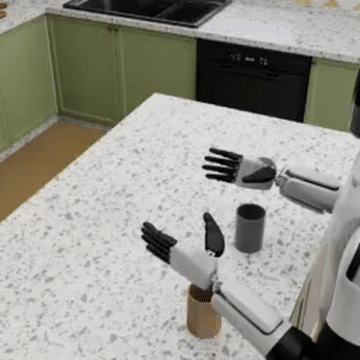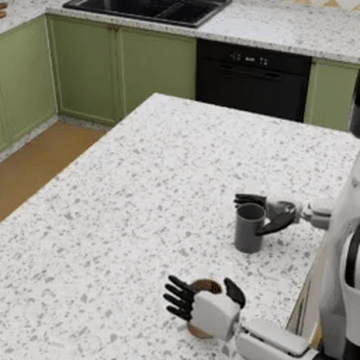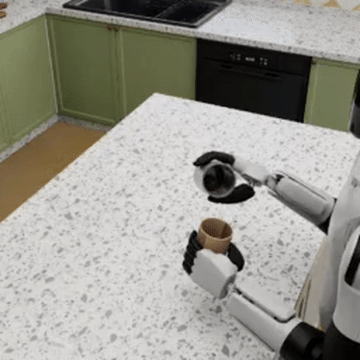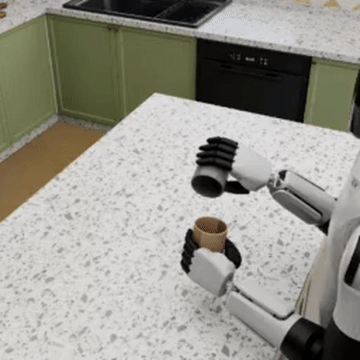
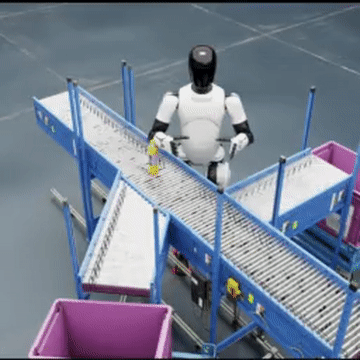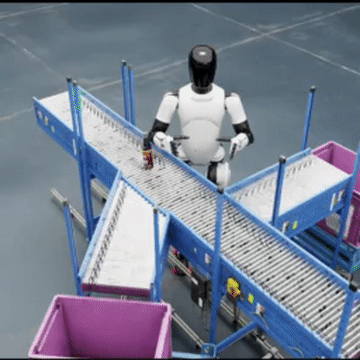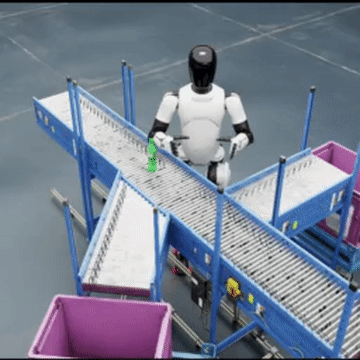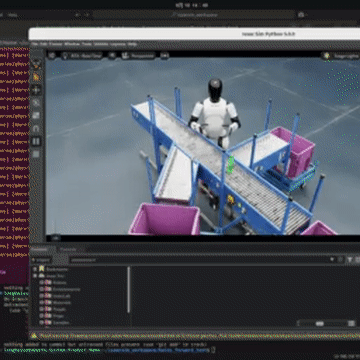
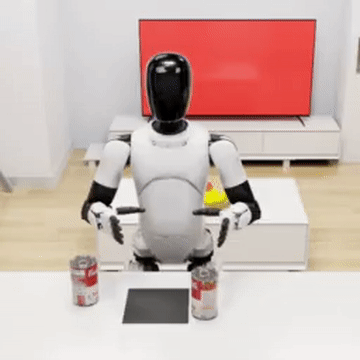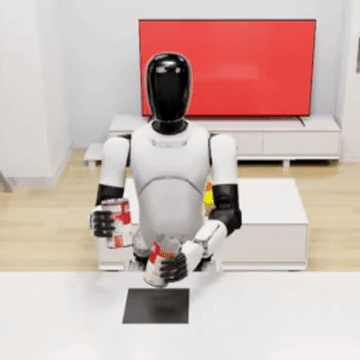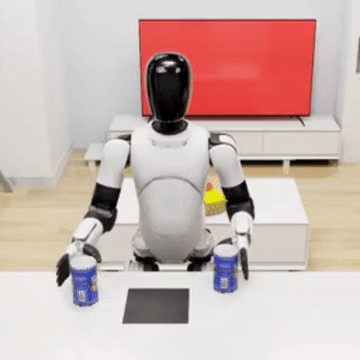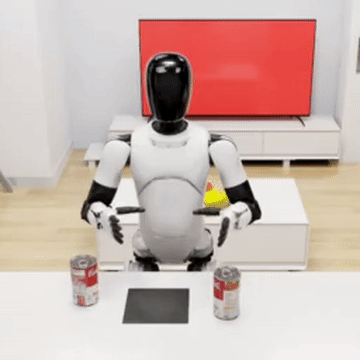
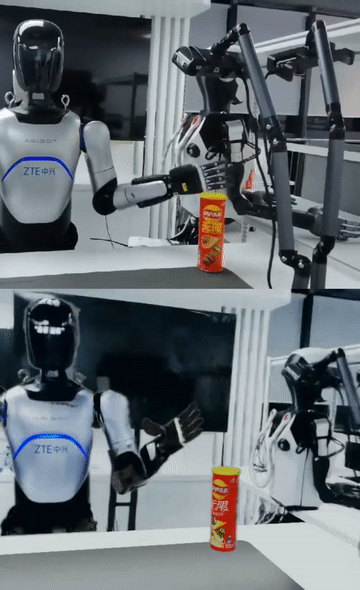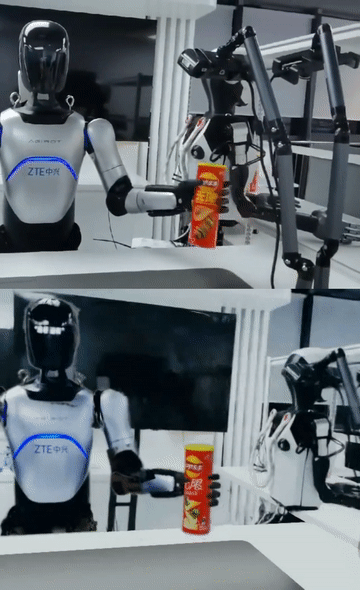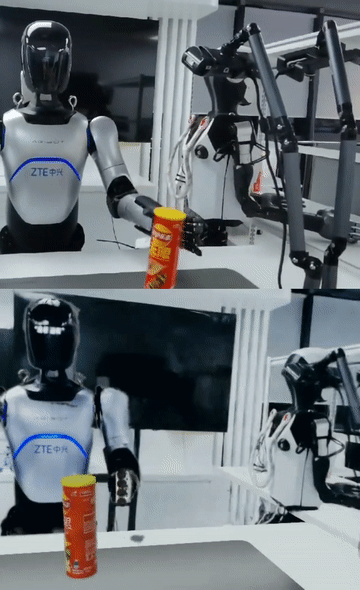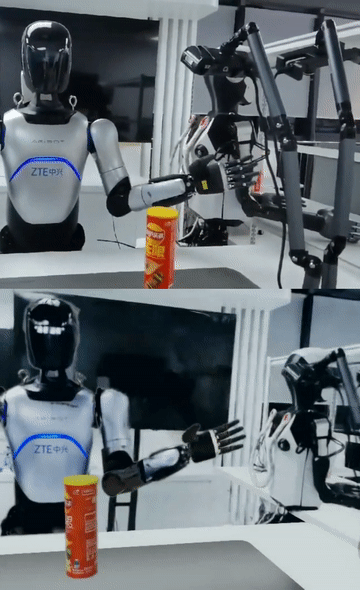
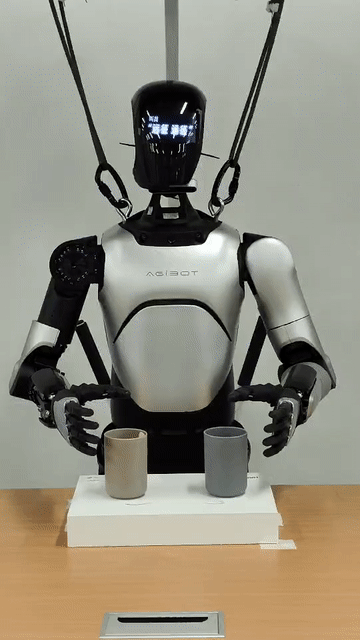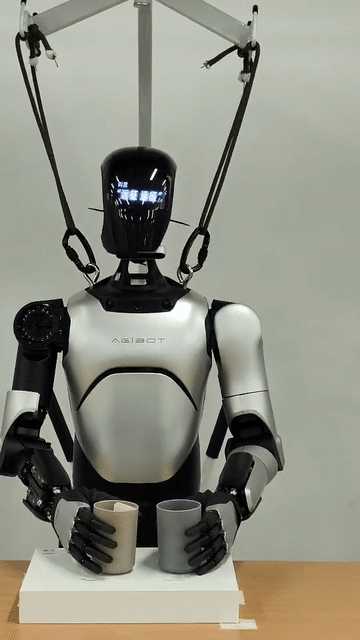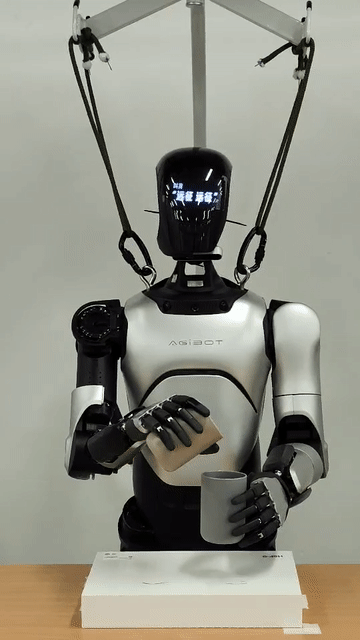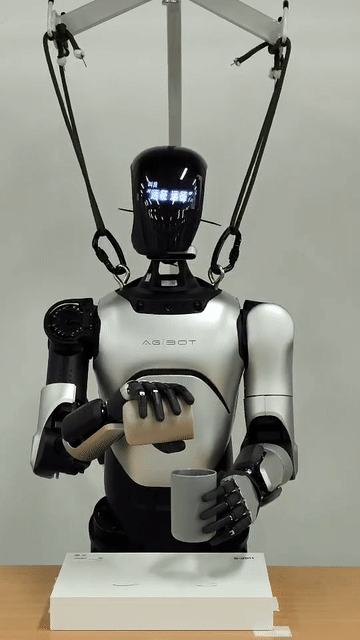
We propose RealMirror, a comprehensive, open-source embodied AI VLA platform. RealMirror builds an efficient, low-cost data collection, model training, and inference system that enables end-to-end VLA research without requiring a real robot. To facilitate model evolution and fair comparison, we also introduce a dedicated VLA benchmark for humanoid robots, featuring multiple scenarios, extensive trajectories, and various VLA models. Furthermore, by integrating generative models and 3D Gaussian Splatting to reconstruct realistic environments and robot models, we successfully demonstrate zero-shot Sim2Real transfer, where models trained exclusively on simulation data can perform tasks on a real robot seamlessly, without any fine-tuning.
E2E VLA Simulation
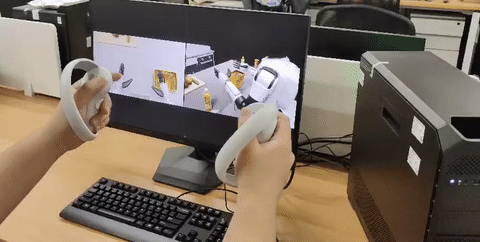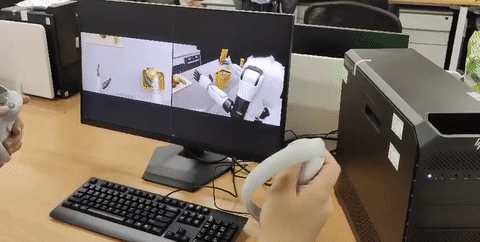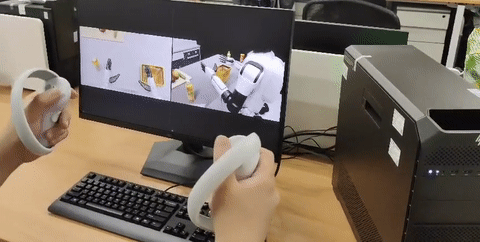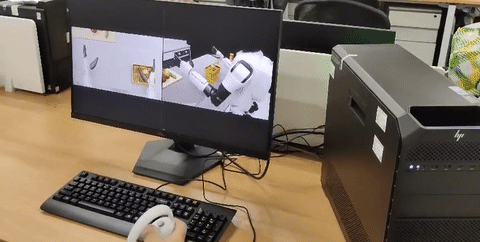
We build an efficient, low-cost data collection, model training, and model inference system that enables end-to-end VLA research without requiring a real robot.
VLA Benchmark
We propose a dedicated VLA benchmark for humanoid robots that facilitates model evolution and fair comparison through extensive experiments and automated evaluation.
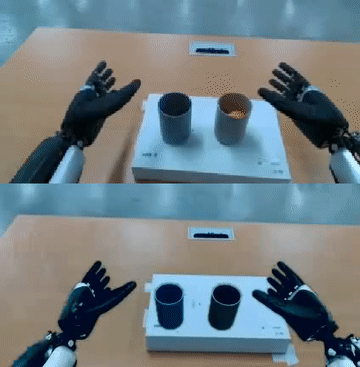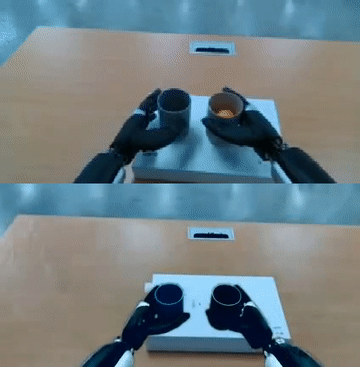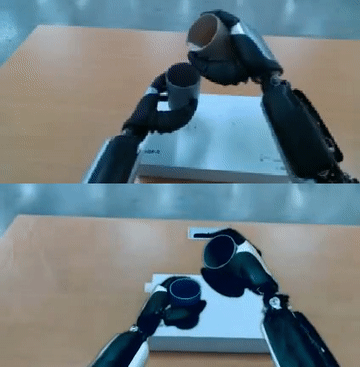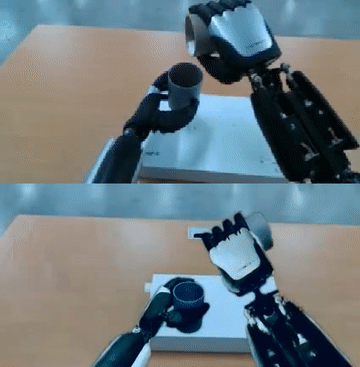
Sim2Real Zero-Shot
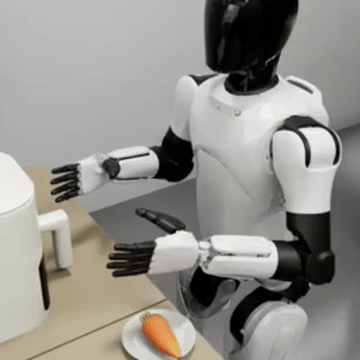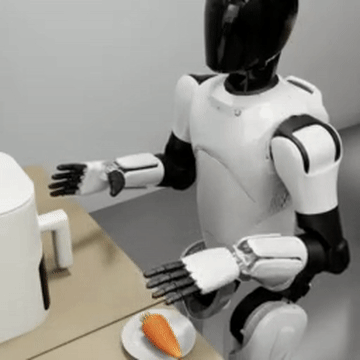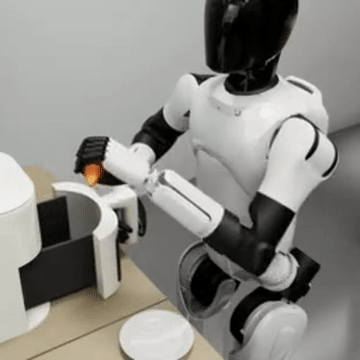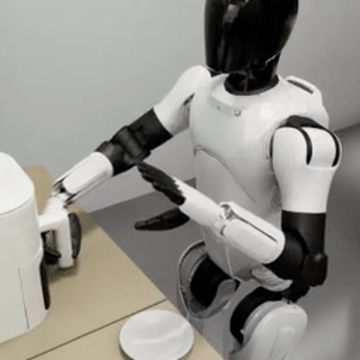
We demonstrate the feasibility of zero-shot Sim2Real by integrating generative models and 3DGS to reconstruct realistic environments and robot models.
Open Source
Our platform's capabilities will be fully open sourced, and we will provide a detailed sim2real solution to accelerate full stack research in the VLA field.
Display Video
Main Contributions
Pipeline Overview
Remote Operation Example
Inference Examples
Sim2Real Zero-Shot
Paper
Special thanks:
AGiBot provides A2 robot model and open-source support
BibTeX
        @article{tai2025realmirror,
          title={RealMirror: A Comprehensive, Open-Source Vision-Language-Action Platform for Embodied AI},
          author={Tai, Cong and Zheng, Zhaoyu and Long, Haixu and Wu, Hansheng and Xiang, Haodong and Long, Zhengbin and Xiong, Jun and Shi, Rong and Zhang, Shizhuang and Qiu, Gang and others},
          journal={arXiv preprint arXiv:2509.14687},
          year={2025}
        }